A 36-cell pack designed around the owned 40 A BMS, with a fixed mechanical interface for the chassis.
Design
Standalone 6S6P mechanical design complete
Integration
Received in verified R12 v5 robot CAD
Physical build
Fit, welds and electrical tests ahead
Configuration
6S6P · 30 Ah nominal
Nominal energy
657 Wh
Core size
149.2 × 146 × 111.1 mm
Make the battery its own design.
I wanted the battery finished as a standalone assembly so the chassis could be designed around a stable interface. The pack uses an aligned 6 × 6 grid of EVE 50E cells and the JK 40 A BMS I already own.
The finished core is 146 mm wide. Fixed lead geometry brings the occupied envelope to 163.2 × 146 × 111.1 mm. Holders, the supported BMS carrier, insulation, nickel geometry, restraints and service space are documented together.
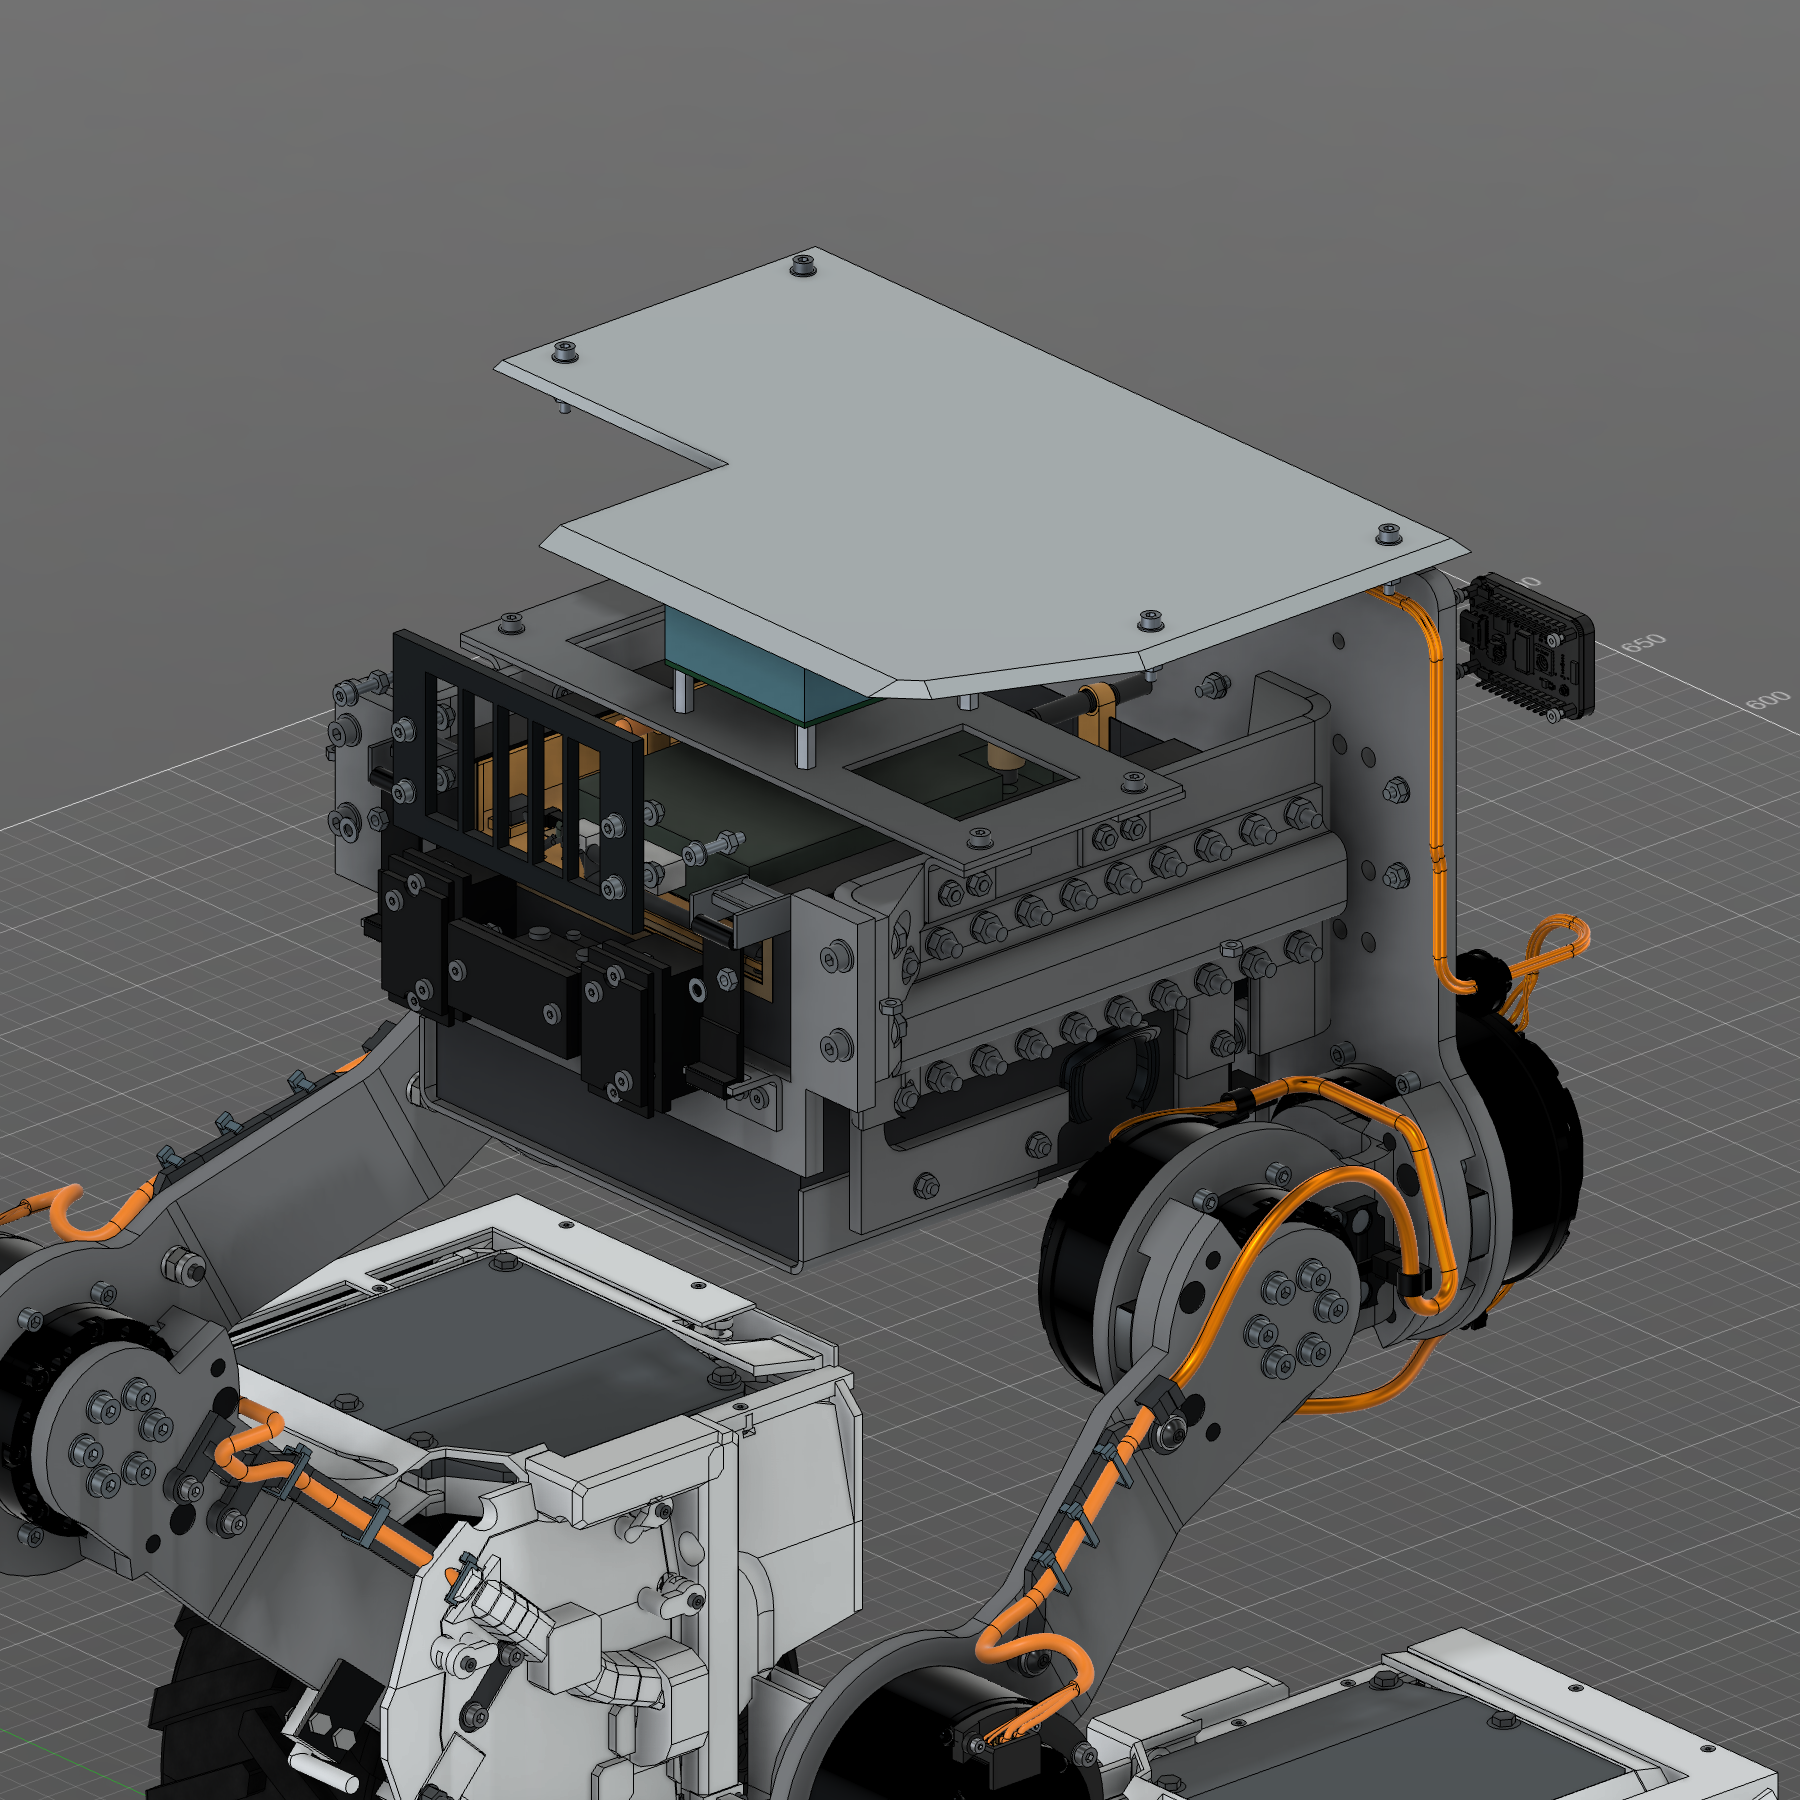
The receiving chassis is now complete in R12 version 5. Braced cheeks, inward returns and a supported tray bring the complete pack into the saved assembly. Source comparison, native motion and actual editable-archive reopening support the delivered CAD; fabrication and electrical qualification remain ahead.
Local receiving / integration pending
Keep charging accessible as the upper body changes.
The builder’s review requires an accessible rear-left XT30 after revising AIRY and its shroud. E04 V7 records local mechanical receiving for its sideways connector and withdrawal path. Full robot installation, copper routing, charging protection and physical power tests remain open.
Candidates / routing pending
Bring the power boards into the receiving set.
The E04 carrier, compact depth regulator, distribution and manual-charge candidates are now included in a common receiving index. Copper routing, full mated fit, source protection and physical charging/thermal behavior remain open.
Charging / power work in progress
Charge inside the chassis, with accessible power interfaces.
The builder selected a rear-left XT30 charge connection and the adjustable voltage/current supply already available. Separate compute distribution and charge-board work are active. Physical charging, protection and supply acceptance remain open; future dock/data ports are space reservations.
Integrated CAD complete
The frame now fits the complete pack.
R12 cloud v5 brings the finished pack interface into a rebuilt internal chassis. The actual editable archive was reopened and checked. This closes receiving-CAD work; physical fit, fabrication, welds and powered acceptance remain separate.
Integration in progress
Resume around the finished pack.
The main CAD cycle resumed with reinforced upper supports and inward front returns. Local chassis source work is delivered; final robot integration, native persistence and physical acceptance remain ahead.
Preserved checkpoint / incomplete
Stop with the work preserved.
Before packing up the MacBook, I asked Codex to stop and preserve the partial Fusion state. Its local recovery archive was reopened and checked. This is an incomplete checkpoint, with no new cloud save or completed robot integration.
Standalone CAD handoff
A fixed pack interface for the chassis.
The isolated 6S6P design is delivered with source STEP geometry, named editable solids, print/forming aids, drawings and a purchasing workbook. The completed handoff records 972 source checks and a fresh rebuild.
Integration in progress
Build the receiving structure around it.
The main robot work is adapting the tray, frame reliefs, removable body and hood around the pack. Component completion does not yet establish a completed integrated robot handoff.
The pack is received in the saved robot CAD.
The completed R12 v5 handoff passes 723 incoming original-source comparisons, including the pack, with native motion and actual local F3D reopening. Cloud processing is complete; cloud download/reopen was not performed. Estimated standalone pack mass remains 3.116 kg; the current whole-robot modeled mass is 16.95 kg, excluding unmodeled main-body power distribution and optional sensor reserve. This is not a weighed robot. Cell dimensions, prints, insulation, welds, protection and current/temperature behavior still need physical evidence.
Completed isolated 6S6P component handoff and October 9 R12 v5 receiving delivery. Earlier travel recovery and resumed studies remain dated history. New charging and compute-power direction is ongoing and does not change the completed pack/chassis baseline. October 10 builder corrections preserve the completed pack/chassis baseline; E04 V7 acceptance is limited to local mechanical receiving.
Design views.
10 Oct 2026Completed receiving CAD + standalone history
The pack inside its rebuilt chassis.
+
Completed R12 v5 native CADR12 v5 · Battery and receiving chassisCompleted receiving CAD around the 6S6P pack. Exterior covers are hidden for this visibility illustration; it does not establish a physical teardown sequence.Standalone CAD / complete6S6P · Isolated pack CADComplete physical-part geometry of the standalone 6S6P design. This is a CAD rendering; fabrication and electrical qualification remain ahead.CAD geometry / assembly study6S6P · Assembly orderExploded component design shows cells, holders, insulation and the BMS carrier. Parts are displaced for review; physical fit, printing, welds and current sharing need qualification.
Parts for this design.
Current integrated 6S6P CAD selection. Owned inventory and modeled parts retain separate statuses; earlier 24-cell selection remains explicitly superseded history in the whole-project register.
The finished design is intended to be open-sourced. Repository, license and release approval are still pending. Downloads will identify the exact component revision they belong to.
Battery & Power planned file releases
File type
Design revision
Availability
Notes
STEP + editable CAD
6S6P interface
Planned
Repository, license and release approval pending.
Print and forming files
6S6P interface
Planned
Repository, license and release approval pending.
Drawings + assembly notes
6S6P interface
Planned
Repository, license and release approval pending.
Editable robot CAD + receiving documentation
R12 v5 integrated receiving CAD
Planned
Completed local/cloud CAD handoff. Repository, license and public design release approval remain pending.
Working BOM CSV downloads above are available now. Editable design and manufacturing packages will be linked after release approval.